Active development2026Author
Botopsy Lab
Failure-first robotics education
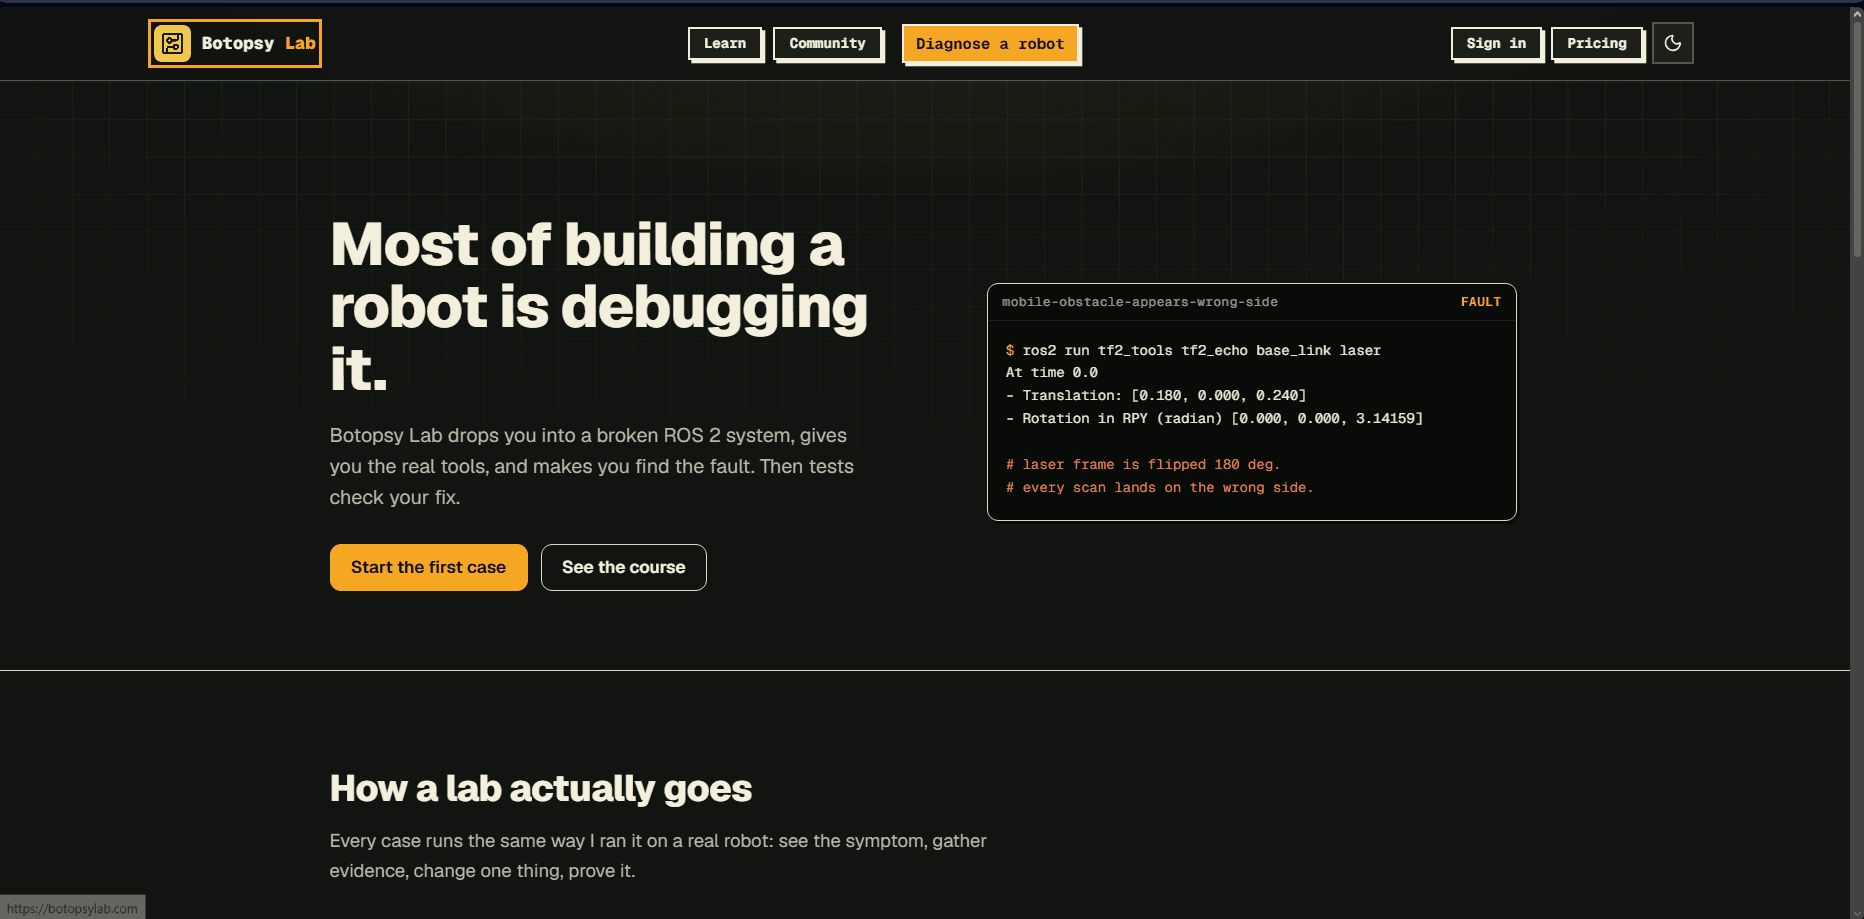
Students get a broken robot, diagnose it, repair it, and prove the fix, because that is the loop the job actually consists of.
Problem
Robotics teaching usually hands a student a working system and asks them to extend it. The actual job is the opposite: something is broken, the logs are unhelpful, and the skill is narrowing it down.
Setting up ROS is also the first thing that stops people, and it teaches nothing.
What I built
An environment where the robot is already broken, and grading checks that you proved the fix.
- Browser-accessible ROS and ROS 2 environments, no local install
- VM checkpoints with save and resume, so a lab can be left and returned to
- Six courses, 96 graded labs planned
- Diagnose → modify → test → prove loop with automated grading
- A separate teacher-led curriculum for grades 3 to 8
Limitations and failure modes
- Course and lab counts are the plan, not the shipped total.
Gallery
Attribution
- Built by me
- The platform, curriculum design and the grading model.
Related
- RosScope
ROS 2 fleet diagnostics, an oscilloscope for the graph